Force-controlled 6-DOF robot
Ph.D. work on path planning and isotonic/isokinetic force control for an NIH-funded physical-therapy robot that physically interacts with people.
Humanoid Robotics · State Estimation · Control
I am Sinan Karahan, a robotics scientist and engineering leader. I build the sensing, state estimation, and control that humanoid and mobile robots need to perceive their own motion and act safely in the physical world, proven in production on iPhone, IMU chips, satellites, and autonomous trucks.
Humanoid robotics & Physical AI
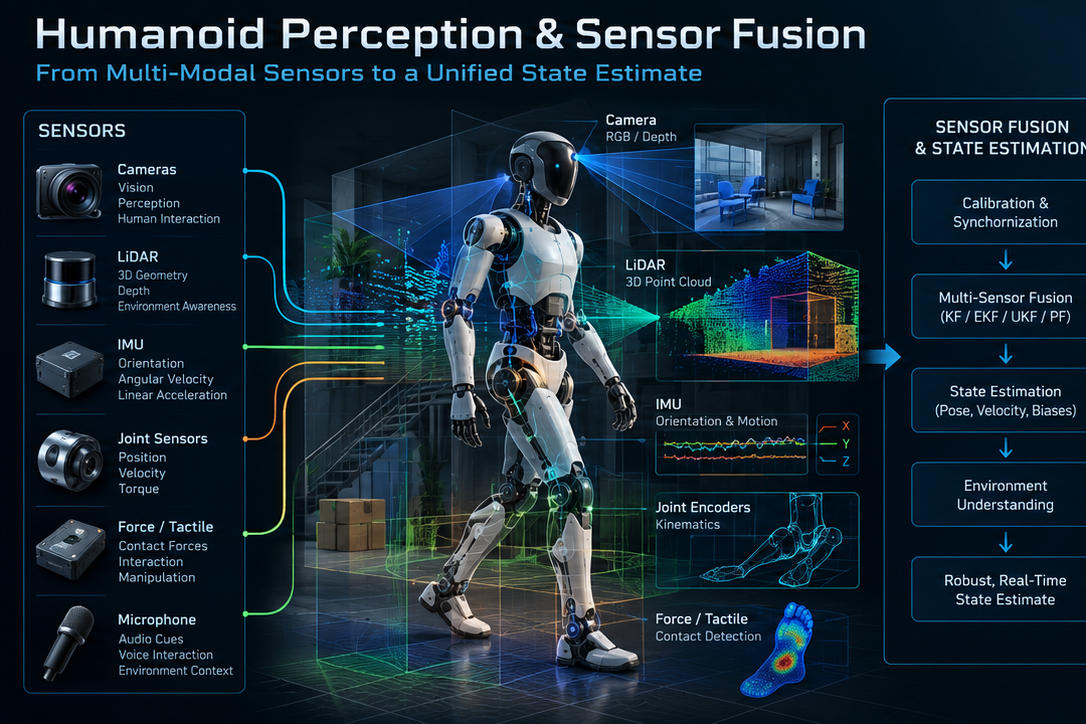
A humanoid has to solve the problems I have shipped solutions for: fusing imperfect sensors in real time, estimating its own state, calibrating hardware in the field, and controlling a physical system safely. The difference is the body, not the mathematics.
Already proven on robots
Ph.D. work on path planning and isotonic/isokinetic force control for an NIH-funded physical-therapy robot that physically interacts with people.
Kinematics, dynamics, and control for a robotic surgical catheter at Hansen Medical.
Kinematics, dynamics, trajectory planning, and control for an articulated industrial robot at Carbon Robotics.
Co-inventor of U.S. Patent 11,680,823 on sensor calibration for mobile-robot navigation; graduate robotics instructor at Santa Clara University.
IMU, vision, LiDAR, joint sensing, force and tactile feedback.
Orientation, pose, velocity, bias, contact state, and probabilistic sensor fusion.
Kinematics, dynamics, calibration, coordinate frames, and physical constraints.
Trajectory generation, model-based control, balance, disturbance rejection, and real-time execution.
Application domains
Whole-body motion, manipulation, calibration, sensing, and safe operation around equipment and people.
Navigation, perception, dynamic state estimation, manipulation, and robust operation in changing environments.
Human-aware perception, motion planning, sensor fusion, and adaptive control for unstructured spaces.
Motion understanding, force-aware control, sensing, and algorithms that connect physical behavior with human intent.
About
My work answers one question across many machines: where am I, how am I moving, and how do I act on that reliably? I have answered it for robots, phones, IMU chips, drones, satellites, passenger cars, and autonomous trucks, and humanoids are the machines where all of it comes together.
I specialize in sensor fusion, filtering and estimation, calibration, localization, robot kinematics and dynamics, motion planning, control, simulation, signal processing, optimization, and machine learning. I have repeatedly moved algorithms from concept and simulation into embedded, real-time, production environments.
Highlights include the first production 9-axis sensor fusion on iPhone, an algorithms organization of 12 Ph.D. and M.S. engineers at TDK InvenSense, a 20-engineer autonomous-driving team at XPeng, spacecraft GNC sensors at E-Space, and production localization for autonomous trucks at Gatik. I also taught graduate robotics at Santa Clara University.
Selected impact
Five domains that define the breadth of my work.
Consumer Electronics
Developed the first production 9-axis Kalman Filter sensor fusion system for iPhone and delivered embedded motion, calibration, and activity algorithms across multiple generations of sensor products, with 4 issued U.S. patents.
Autonomous Driving
Led and developed multi-sensor systems using GNSS, IMU, LiDAR, radar, camera, and wheel odometry for autonomous vehicles, including production truck localization at 2 cm with RTK GNSS and 10 cm with degraded or no GNSS.
Space & Aerospace
Directed spacecraft sensor and actuator development, modeled satellite dynamics and orbital systems, and contributed to NASA air-traffic optimization research.
Robotics
Designed kinematics, dynamics, control, trajectory planning, and force-based exercise algorithms for industrial, rehabilitation, animation, and medical robotics.
Research & Education
Ph.D. research in nonlinear systems, graduate robotics instruction at Santa Clara University, and professional engagement through IEEE, ASME, Sigma Xi, and IFAC.
Technical expertise
Career timeline
Filter the timeline by domain, then open any role for a concise account of the work, technical focus, and impact.
Autonomous systems · Localization
Technical Lead, Mapping and Localization
Develops production localization and state-estimation systems, combining multiple sensing modalities in real-time software.
Consulting · Estimation & GNC
President
Advised clients on sensing, estimation, and control problems across autonomy, space, and AR/VR.
Space systems · GNC
Director, GNC Sensors & Actuators
Directed development and evaluation of spacecraft guidance, navigation, and control sensors and actuators.
Sensors · Embedded algorithms
Director, Algorithms
Led algorithm development for motion sensing, sensor fusion, calibration, and embedded intelligent products.
Autonomous driving · Technical leadership
Principal Research Scientist, Autonomous Driving
Built and led an autonomous-driving research and engineering team spanning localization, perception, planning, control, and simulation.
Autonomous driving · Localization
Lead Research Scientist, Autonomous Driving
Contributed estimation, sensor-fusion, localization, and navigation expertise to autonomous-vehicle development.
Industrial robotics · Control
Director of Robotics and Algorithms
Directed robotics, control, planning, and system-integration work for advanced industrial robotic platforms.
Aerial autonomy · Force sensing
Algorithm Lead · Nixie and NextInput
Short algorithm-lead engagements with two hardware startups.
Motion sensing · Production algorithms
Principal Engineer and Director, Advanced Algorithms
Developed and led embedded sensor-fusion, calibration, and motion-algorithm work for consumer and mobile sensing products.
Consumer electronics · Motion intelligence
Research Scientist / Motion Algorithms Lead
Developed production motion and orientation algorithms for iPhone, including the first production 9-axis Kalman Filter sensor-fusion system.
Robotics · Simulation · Education
Sensor Platforms, NASA Ames, Hansen Medical, Motion Factory, Santa Clara University, UC Davis, and others
Early work established the robotics, dynamics, control, simulation, and teaching foundations that informed later production systems.
Technical portfolio
Selected engineering programs organized by technical challenge rather than employer. Descriptions stay at a public, non-confidential level while showing the methods, system constraints, and leadership scope behind the work.
Production autonomy
Reliable vehicle-state estimation across real roads, imperfect sensors, and production constraints.
Fuse complementary sensing modalities while maintaining accuracy, continuity, observability, and diagnosability in real time.
Probabilistic estimation using GNSS, IMU, LiDAR, cameras, and wheel odometry, supported by simulation, replay, testing, and vehicle integration.
Technical leadership spanning algorithm architecture, software implementation, validation strategy, and cross-functional system integration.
Embedded intelligence
Orientation and motion estimation combining accelerometer, gyroscope, and magnetometer measurements in resource-constrained consumer devices.
Space systems
Sensor and actuator design viewed as part of a complete guidance, navigation, and control architecture.
Robotic systems
Robotic mechanisms and control systems designed around human interaction, physical constraints, and safety.
Industrial robotics
System-level development connecting mathematical models to physical robot behavior and product constraints.
Technical organization
Leadership across localization, perception, planning, control, simulation, and vehicle integration.
Technology matrix
Kalman filters, nonlinear estimation, sensor fusion, calibration, state estimation, localization, attitude estimation
Kinematics, dynamics, motion planning, trajectory generation, control, simulation, optimization
IMU, GNSS, LiDAR, cameras, magnetometers, wheel odometry, force and touch sensors
C++, Python, MATLAB/Simulink, ROS and ROS 2, Linux, embedded and real-time systems
Engineering philosophy
I approach intelligent machines as complete systems: sensing, estimation, planning, control, software, hardware, and validation must reinforce one another.
Strong algorithms matter. Strong interfaces, observability, testability, and failure handling are what make them dependable.
Professional activities
Selected references
Contact
Open to Principal and Staff technical roles and Director / Head of engineering roles in humanoid and mobile robotics, autonomous systems, state estimation, and localization.
Two résumés: Technical for Principal / Staff roles, Leadership for Director / Head roles.
Humanoid Sensor Fusion & State Estimation · 1086 × 724